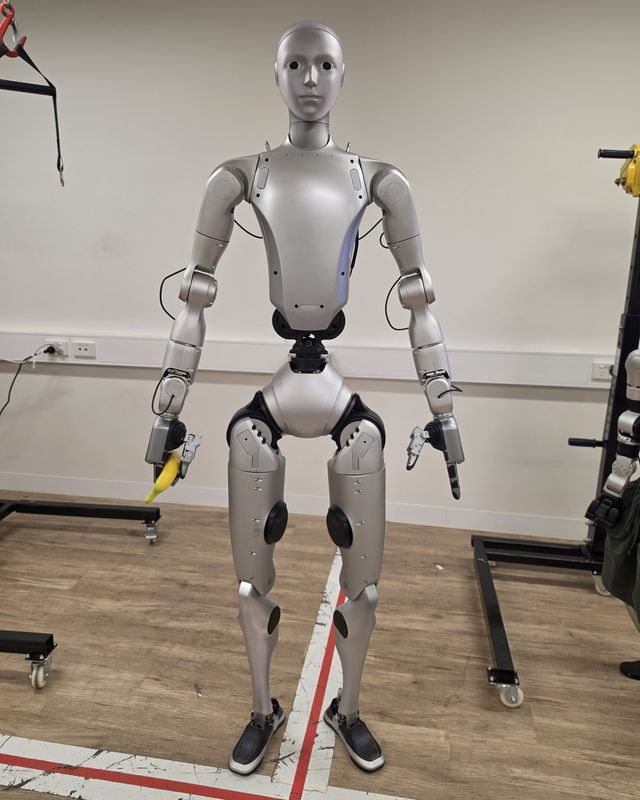
× 1 Humanoid · 1 unit
Unitree H2
- Configuration
- Dex5 dexterous hand
- Research use
- Whole-body and dexterous manipulation research.
Facilities
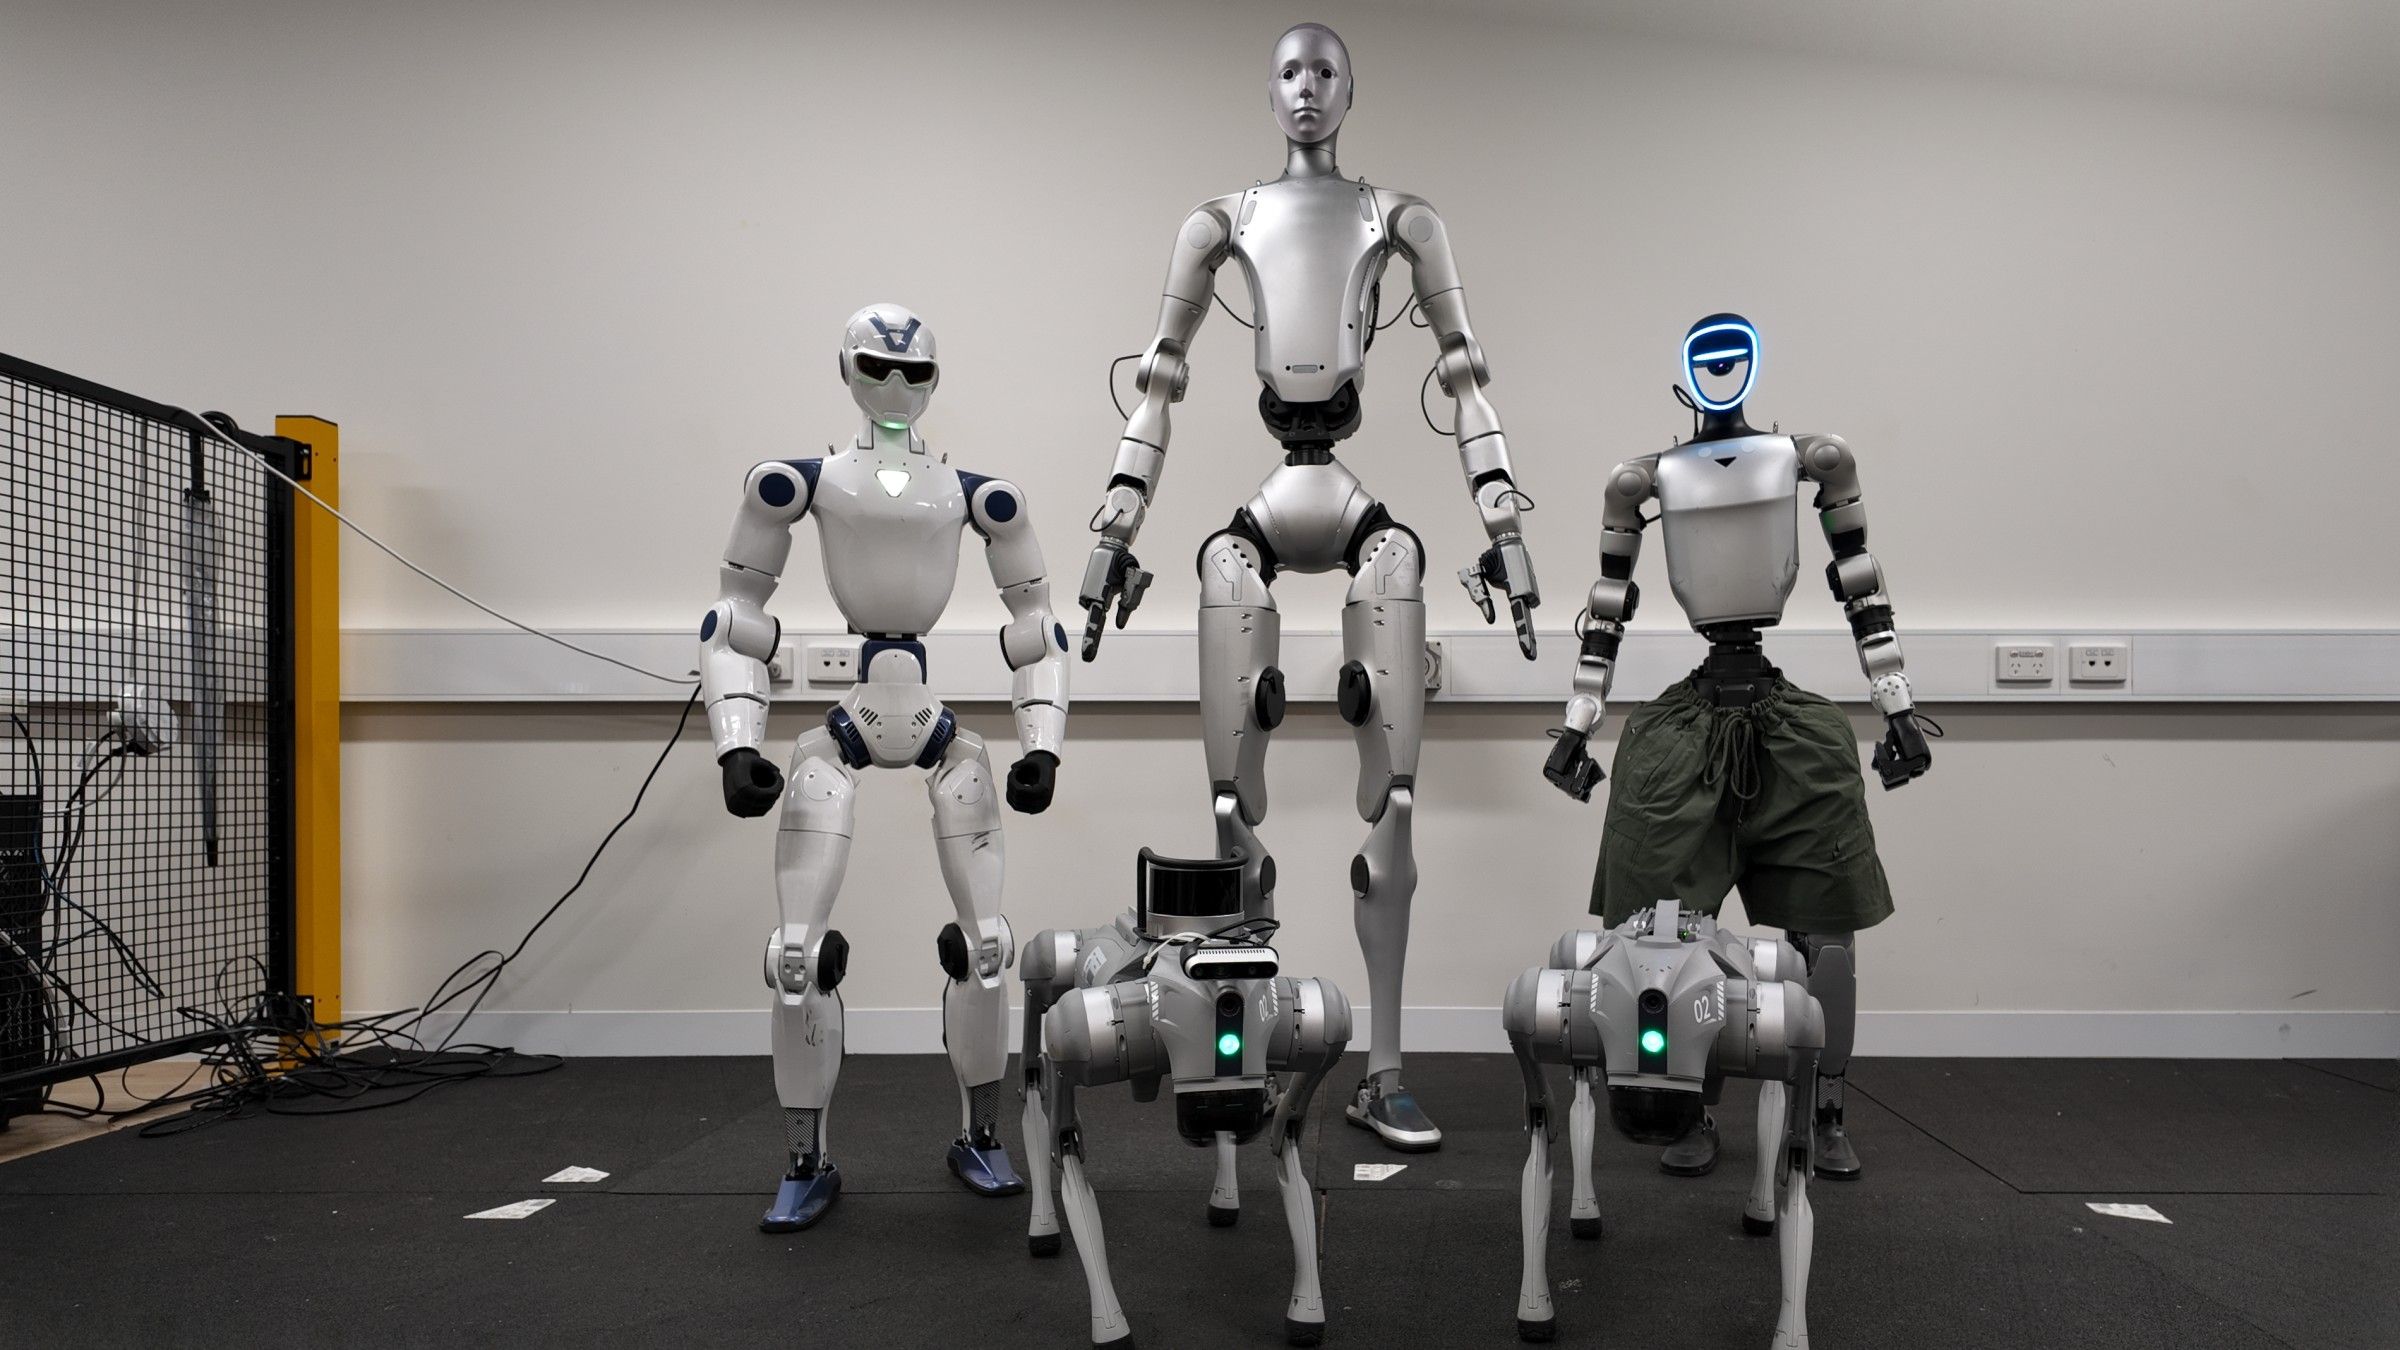
WEAI Lab, a research team at the University of Sydney, works with humanoid and quadruped robots and an on-site AI workstation. This page summarises the resources we currently hold and what we use them for.
1 × Unitree H2 · 1 × Unitree G1 · 1 × Unitree R1 · 2 × Unitree Go2
Current platforms
Current platforms are robots the team holds. Listing a platform does not mean every unit is running at a given time, or that every autonomous capability has been validated on it. Configurations are listed only where confirmed.
× 1 Humanoid · 1 unit
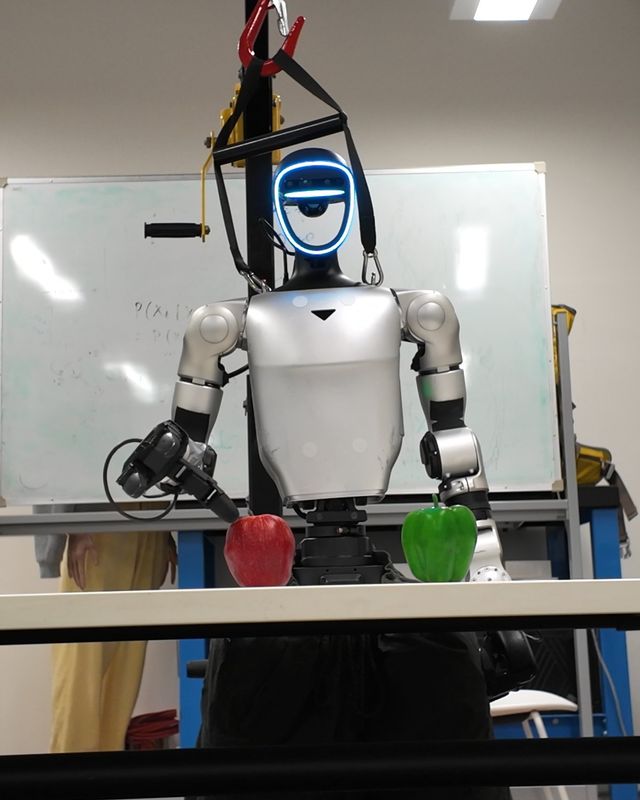
× 1 Humanoid · 1 unit
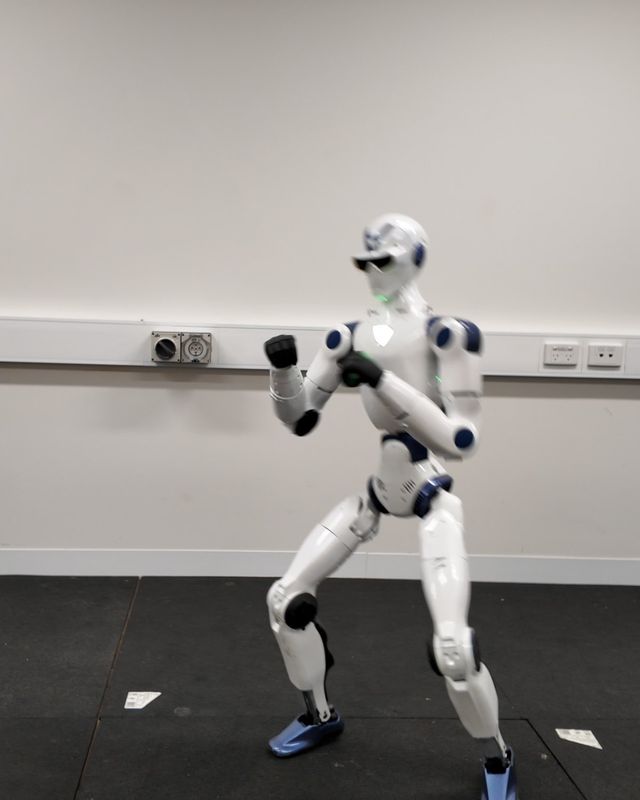
× 1 Humanoid · 1 unit
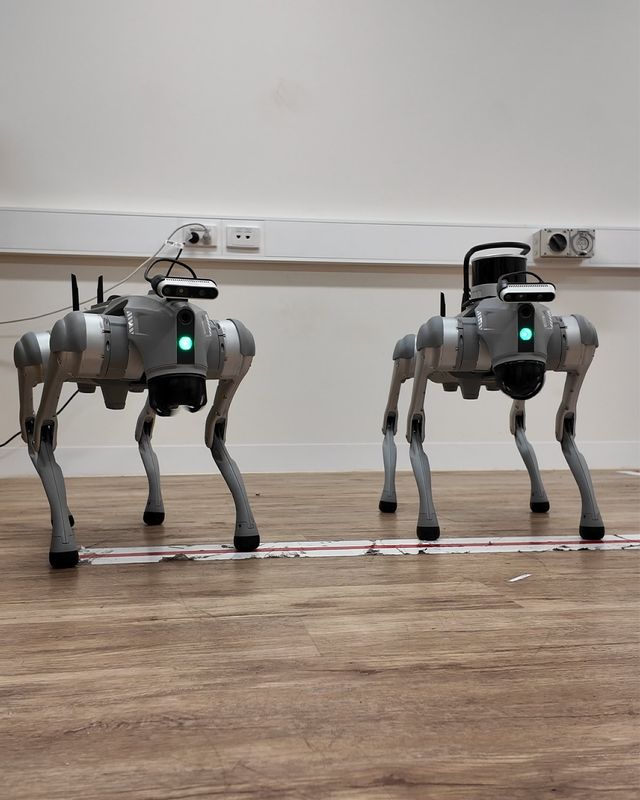
× 2 Quadruped · 2 units
Platforms and research uses
Research use describes what a platform supports in our work. A demonstrated result is listed only when it is linked to published media.
| Platform | Type | Units | Confirmed configuration | Research use | Related research | Demonstrated result |
|---|---|---|---|---|---|---|
| Unitree H2 | Humanoid | 1 | Dex5 dexterous hand | Whole-body and dexterous manipulation research. | — none listed | — |
| Unitree G1 | Humanoid | 1 | Dex3 dexterous hand | Perception, manipulation and embodied AI research. | ||
| Unitree R1 | Humanoid | 1 | — not listed | Humanoid motion control and interactive robotics research. | ||
| Unitree Go2 | Quadruped | 2 | — not listed | Mobile robotics, natural interaction and multi-robot research. | ||
| Total | 3 humanoid, 2 quadruped | 5 | ||||
“—” means no configuration or project link is listed yet. Related research shows confirmed project–platform links only.
Compute
One on-site workstation with 4 × NVIDIA RTX PRO 6000 Blackwell GPUs supports model development, simulation and robotics workflows.
Integration
Experiments bring together visual perception, robot interfaces, control software and the compute above. Our team integrates these components for each experiment, linking on-robot control with the models and tools developed in the lab.
Related research
We develop research prototypes that connect object perception, language instructions, grasp planning and feedback control for tabletop manipulation.
Project investigator: Haonan Zhou
We investigate interfaces that connect human instructions with robot behaviours, supporting interactive demonstrations across mobile and humanoid platforms.
Project investigator: Haonan Zhou
Contact
For research collaboration or questions about these facilities, contact: