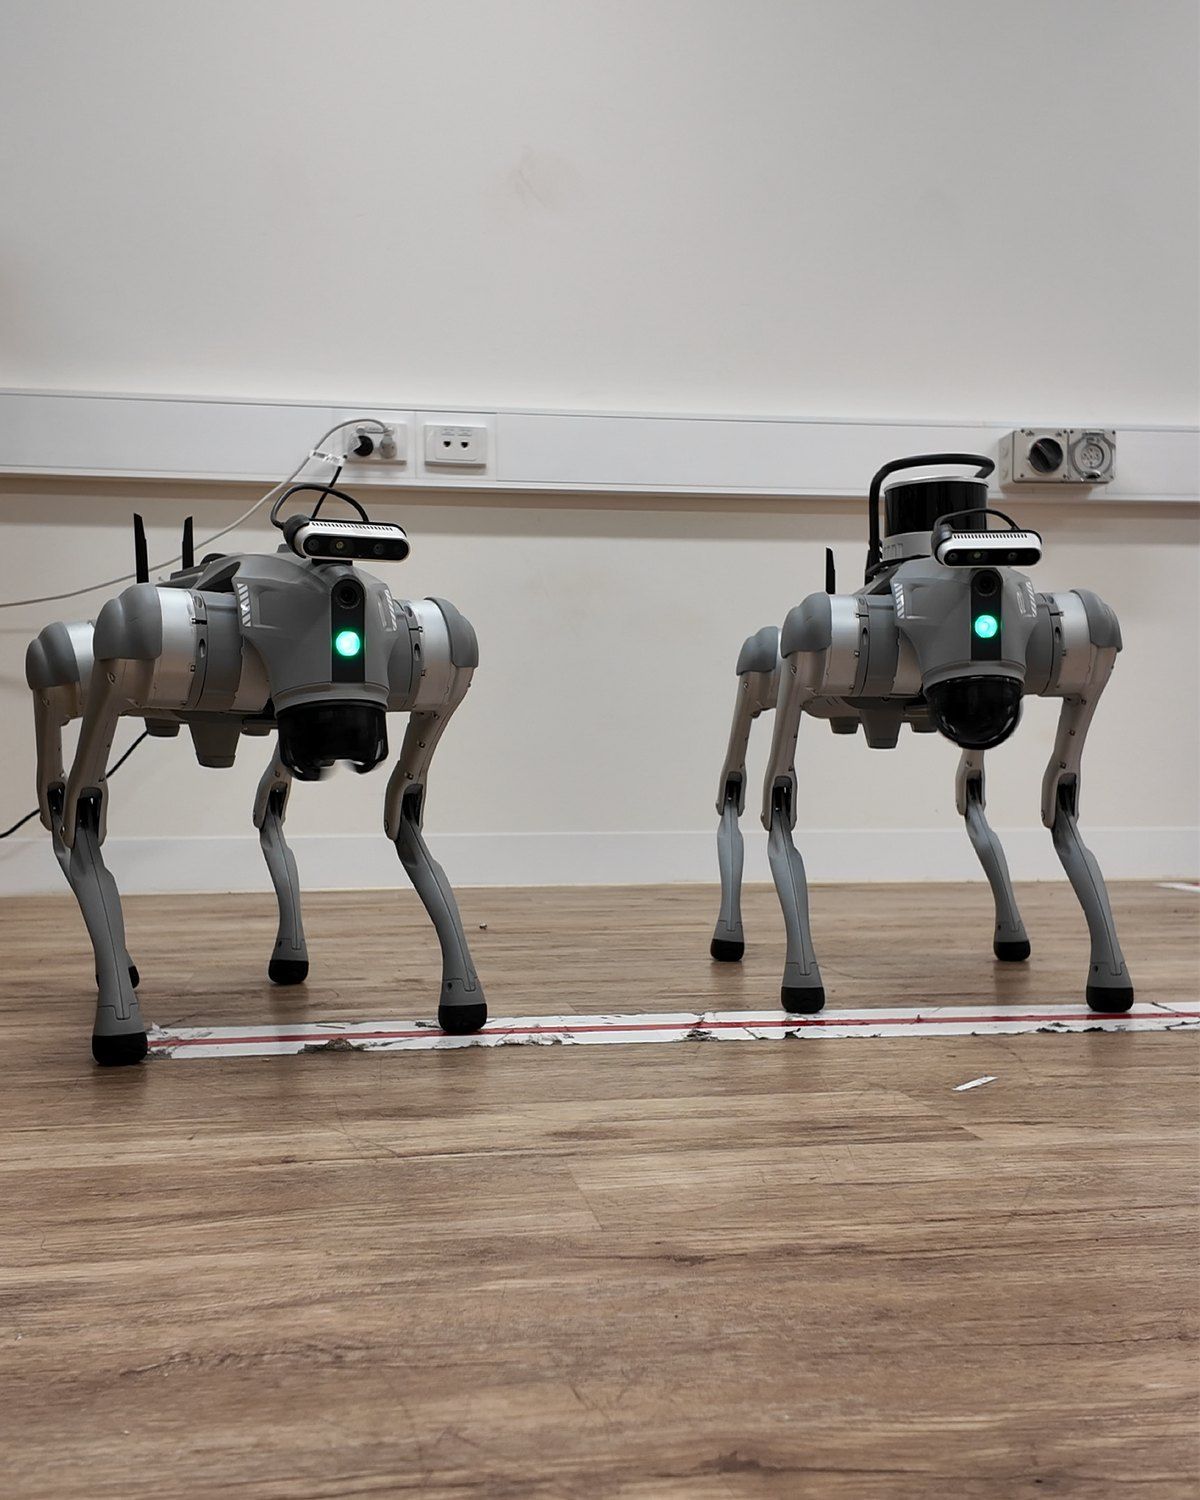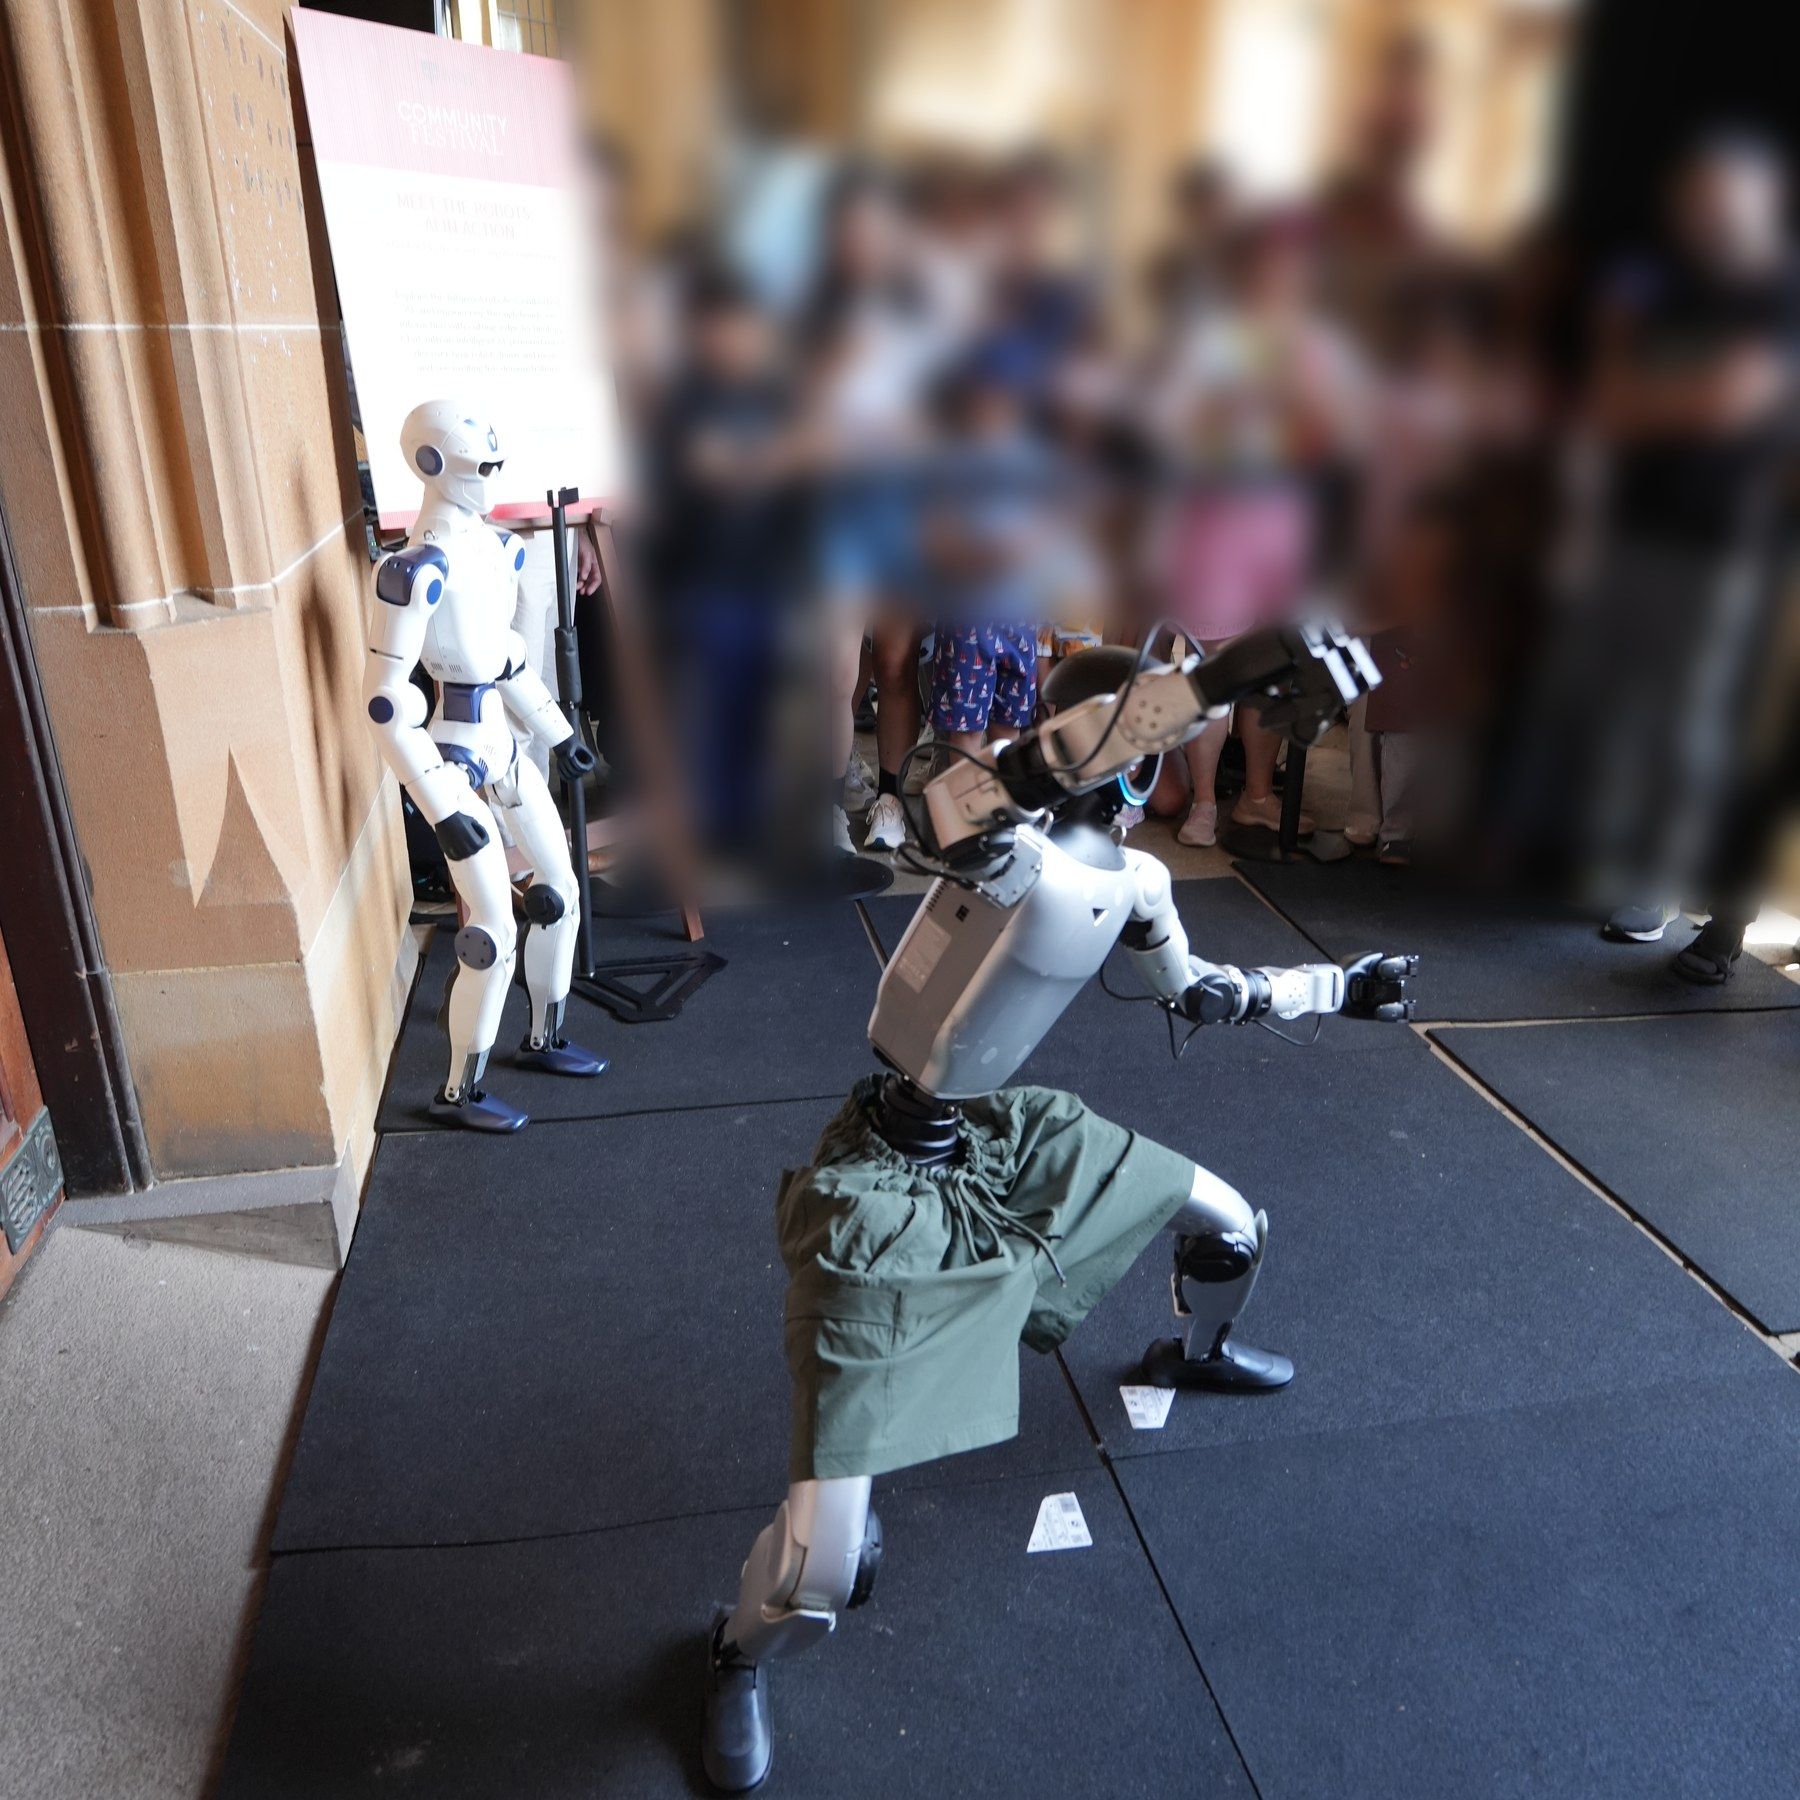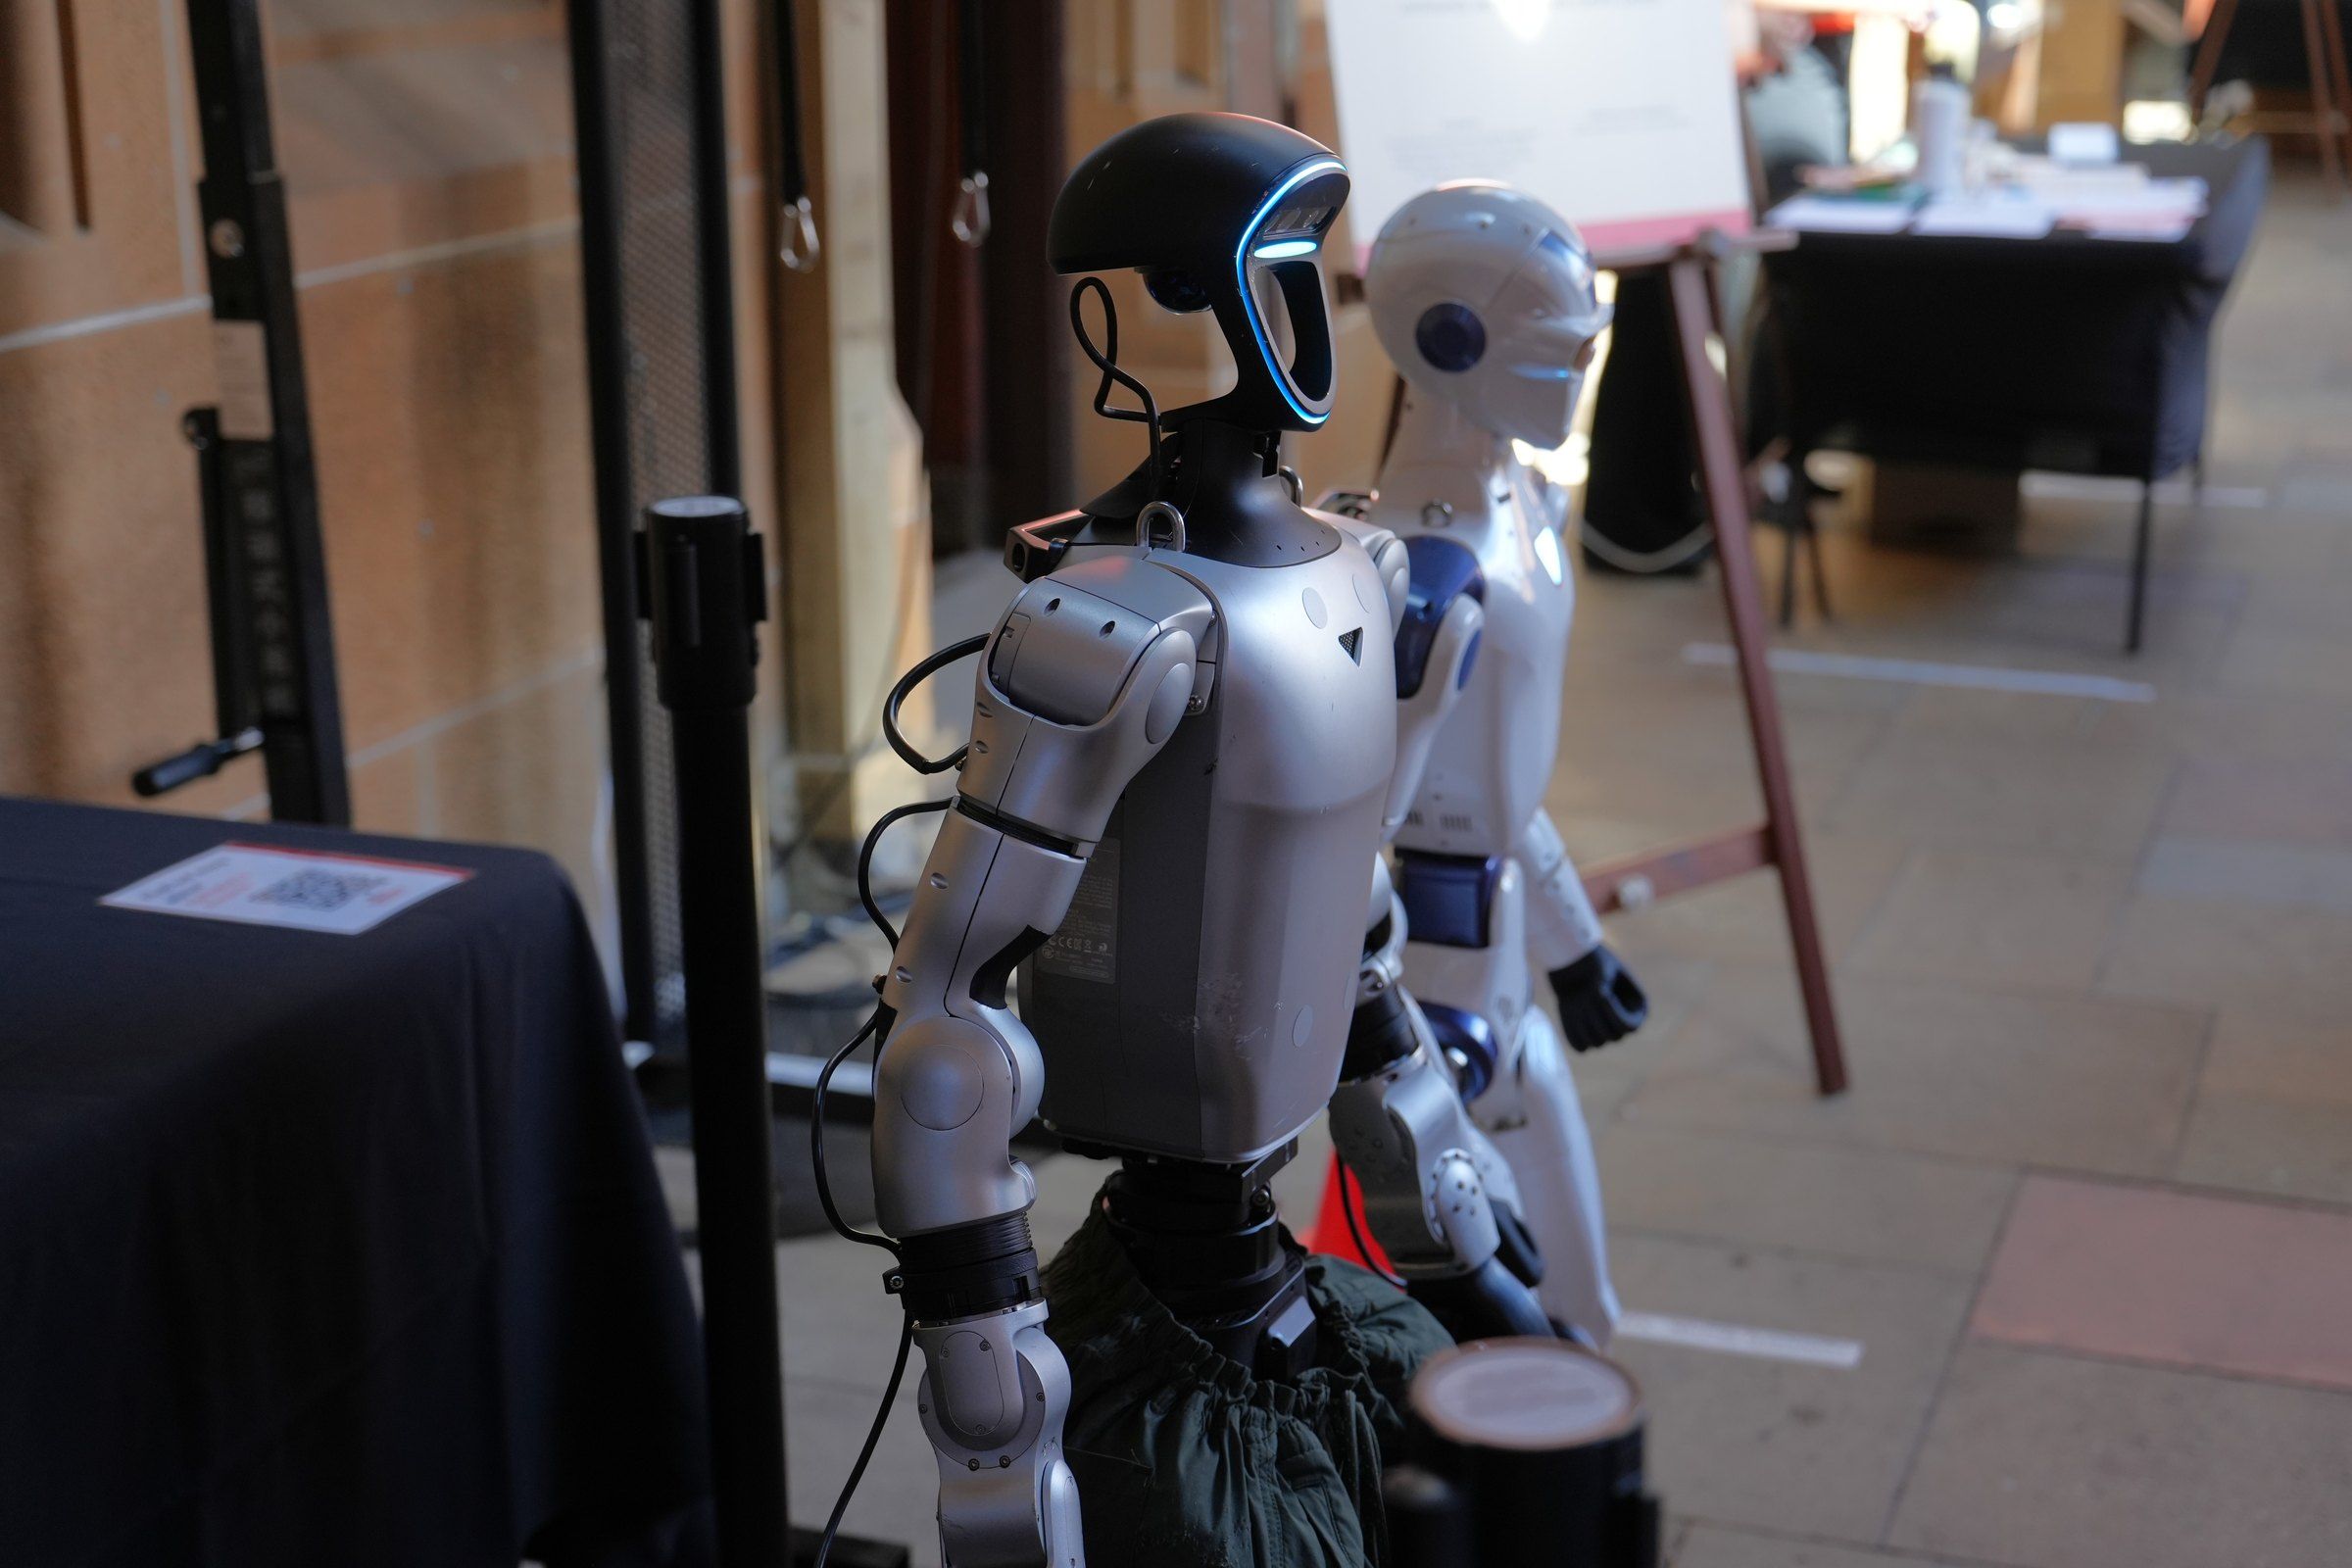
Collaborative Intelligence Across Robots and Networks
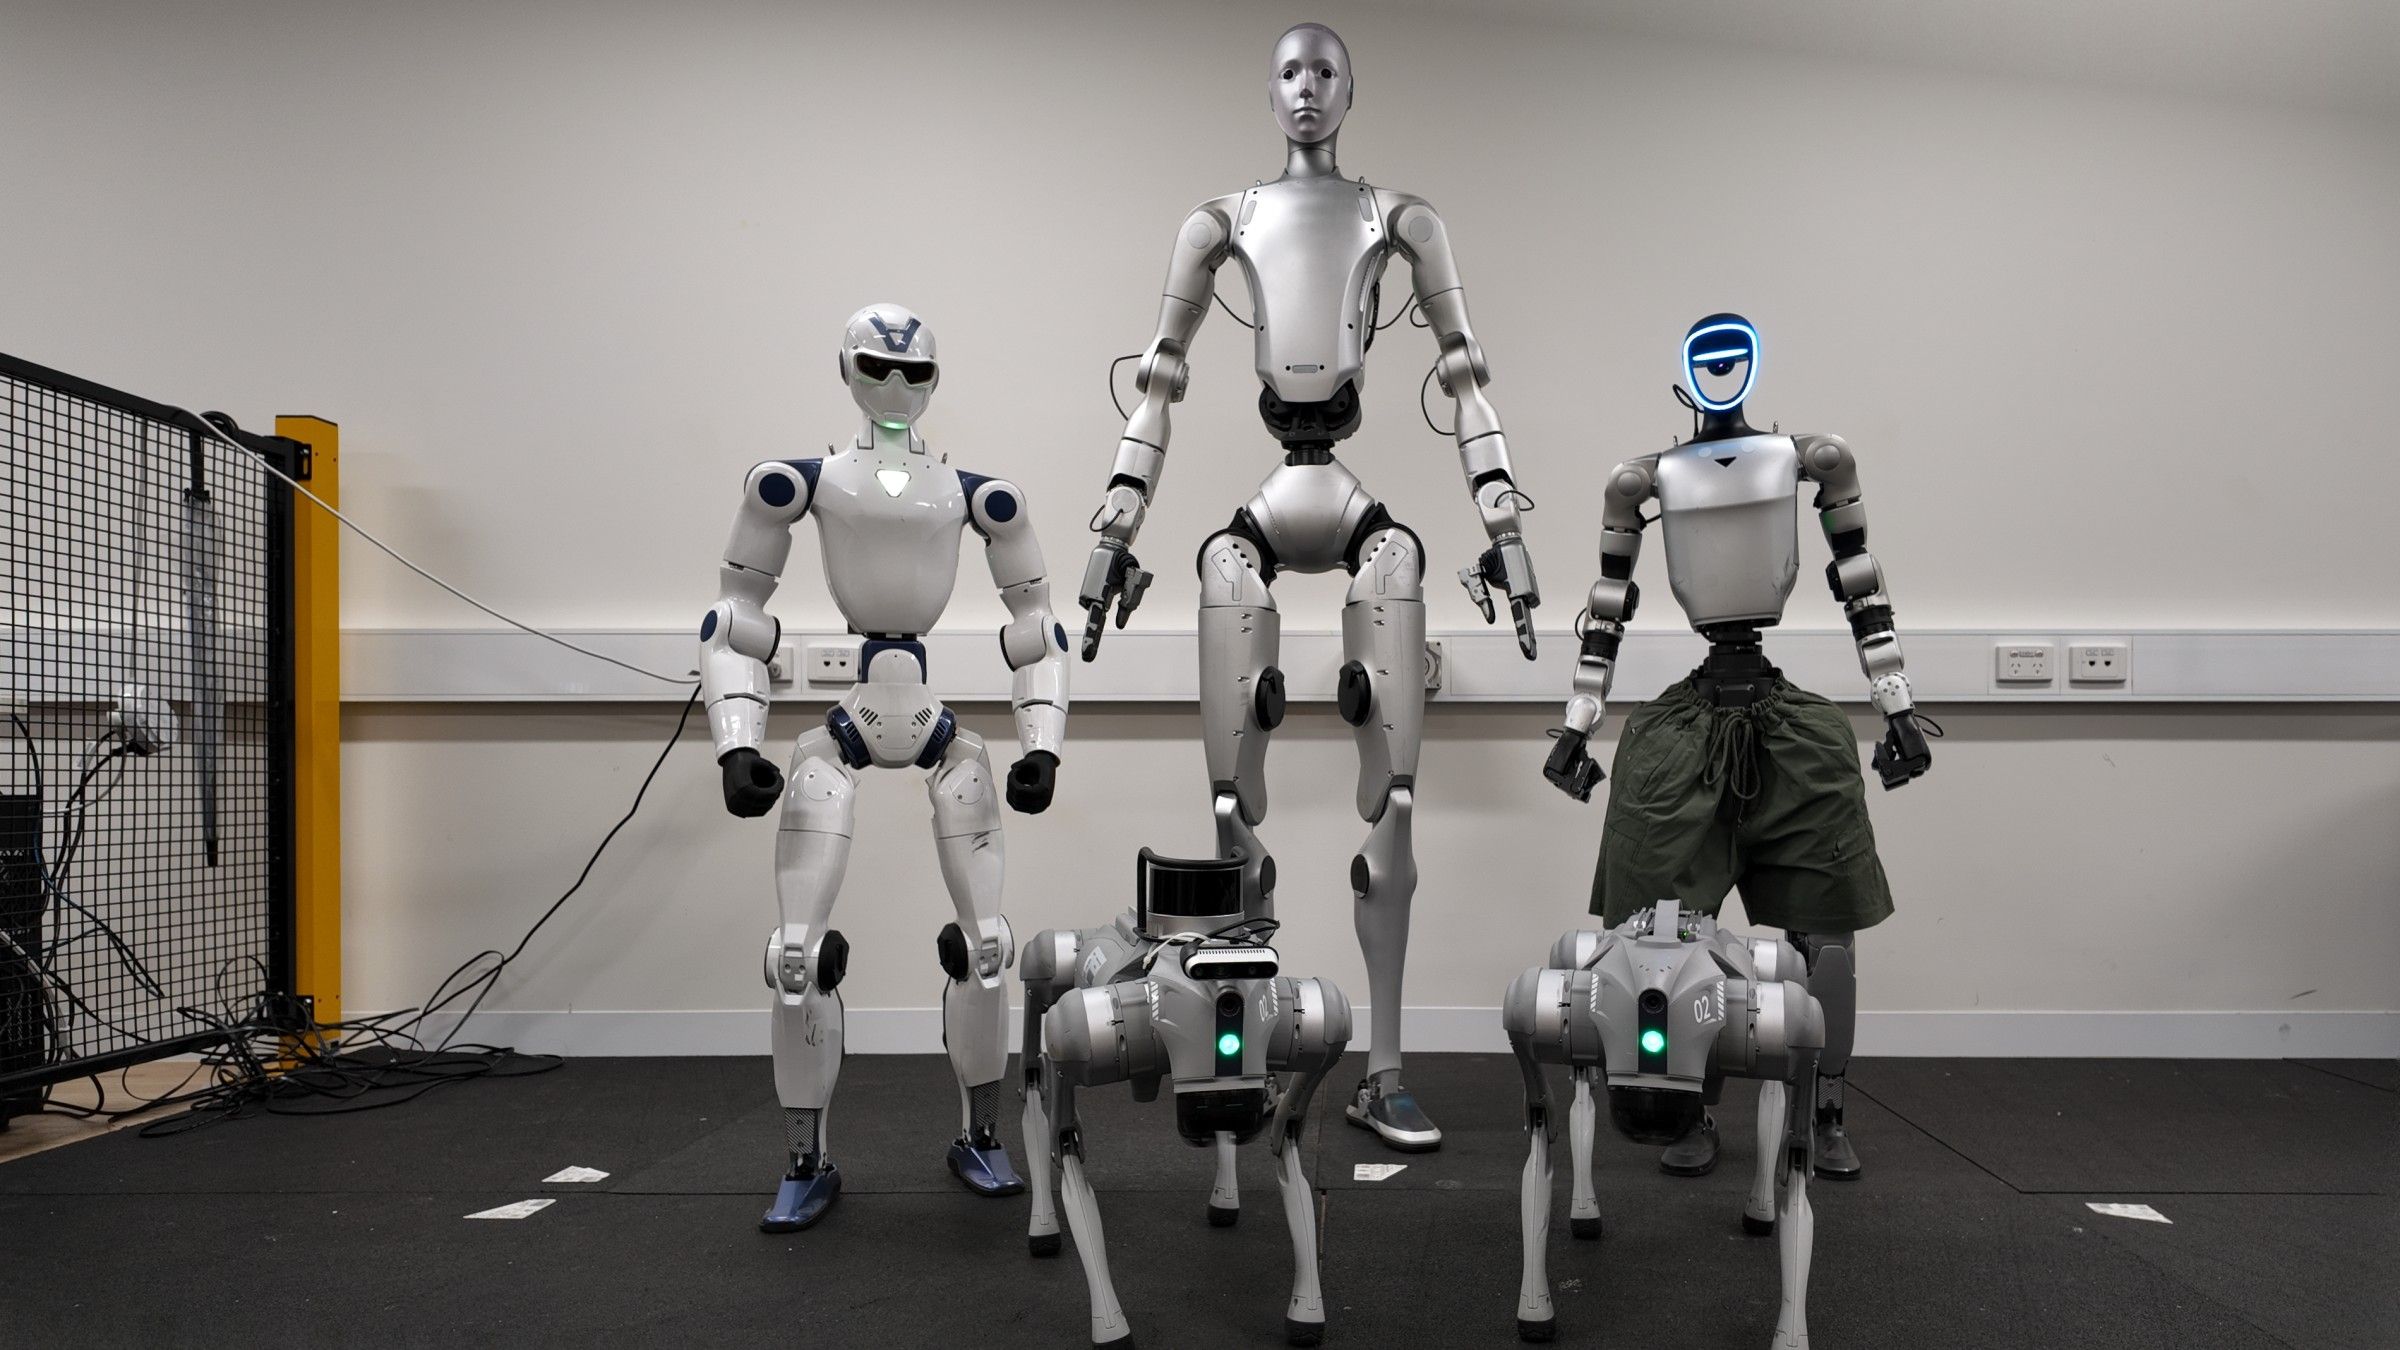
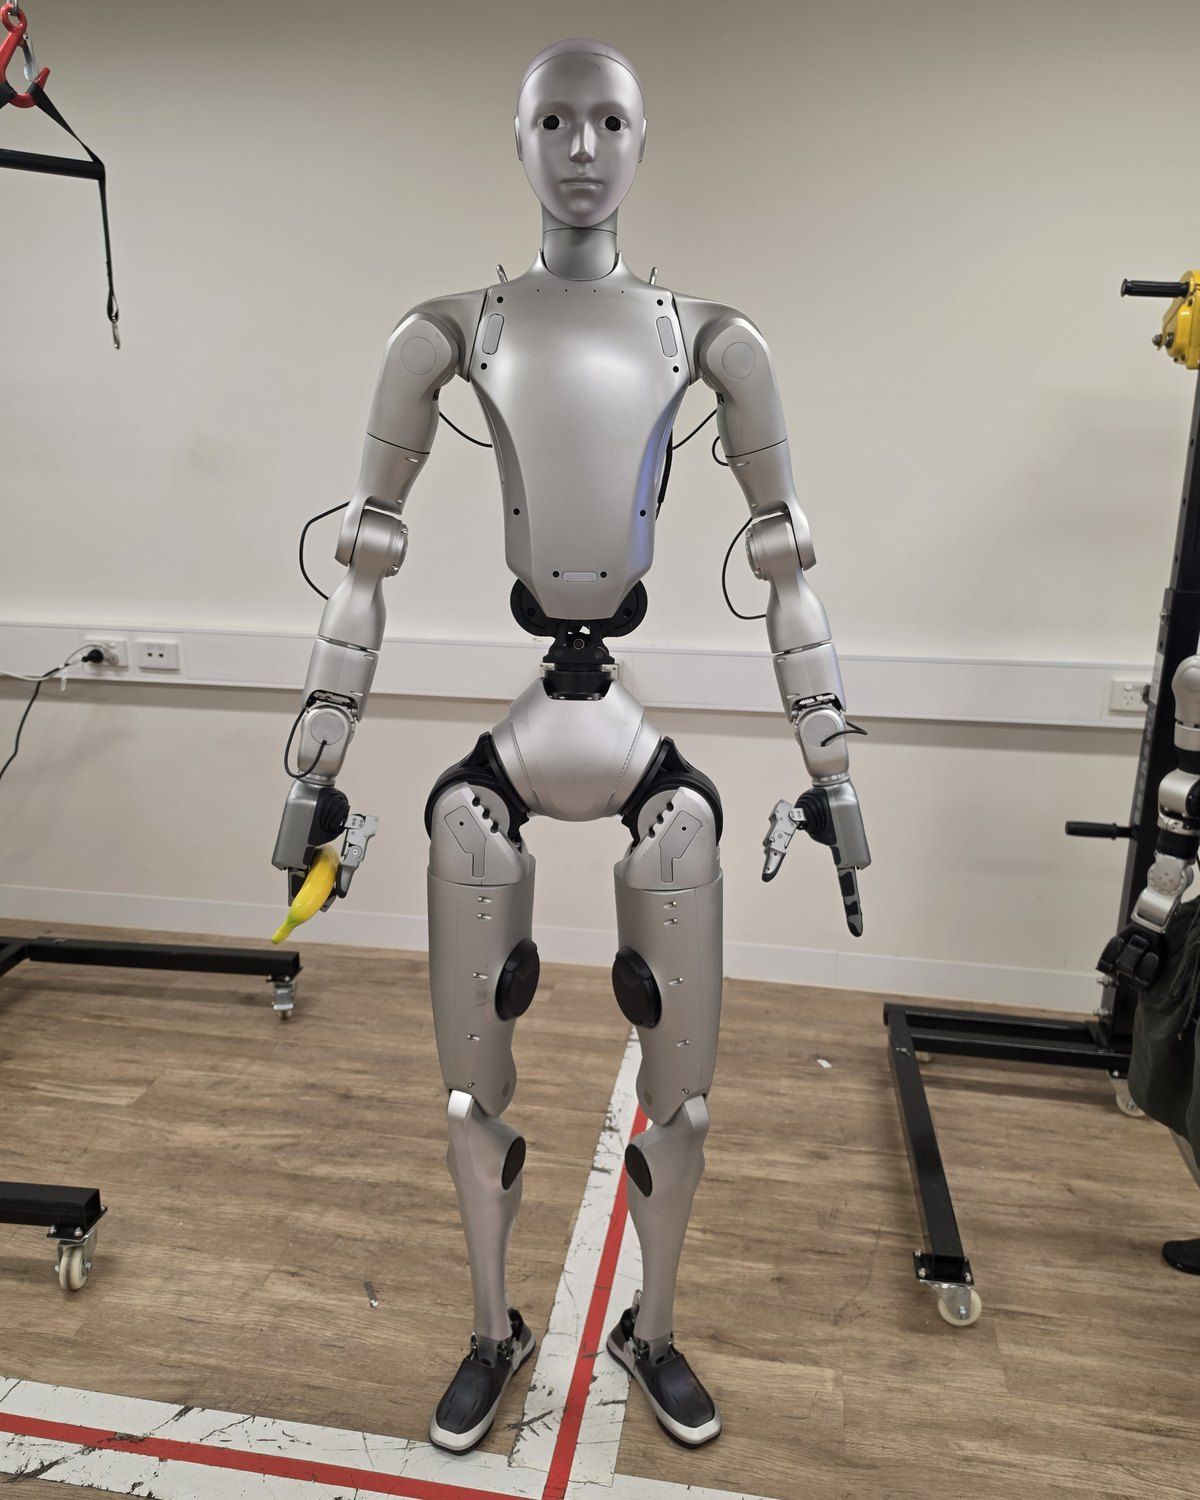
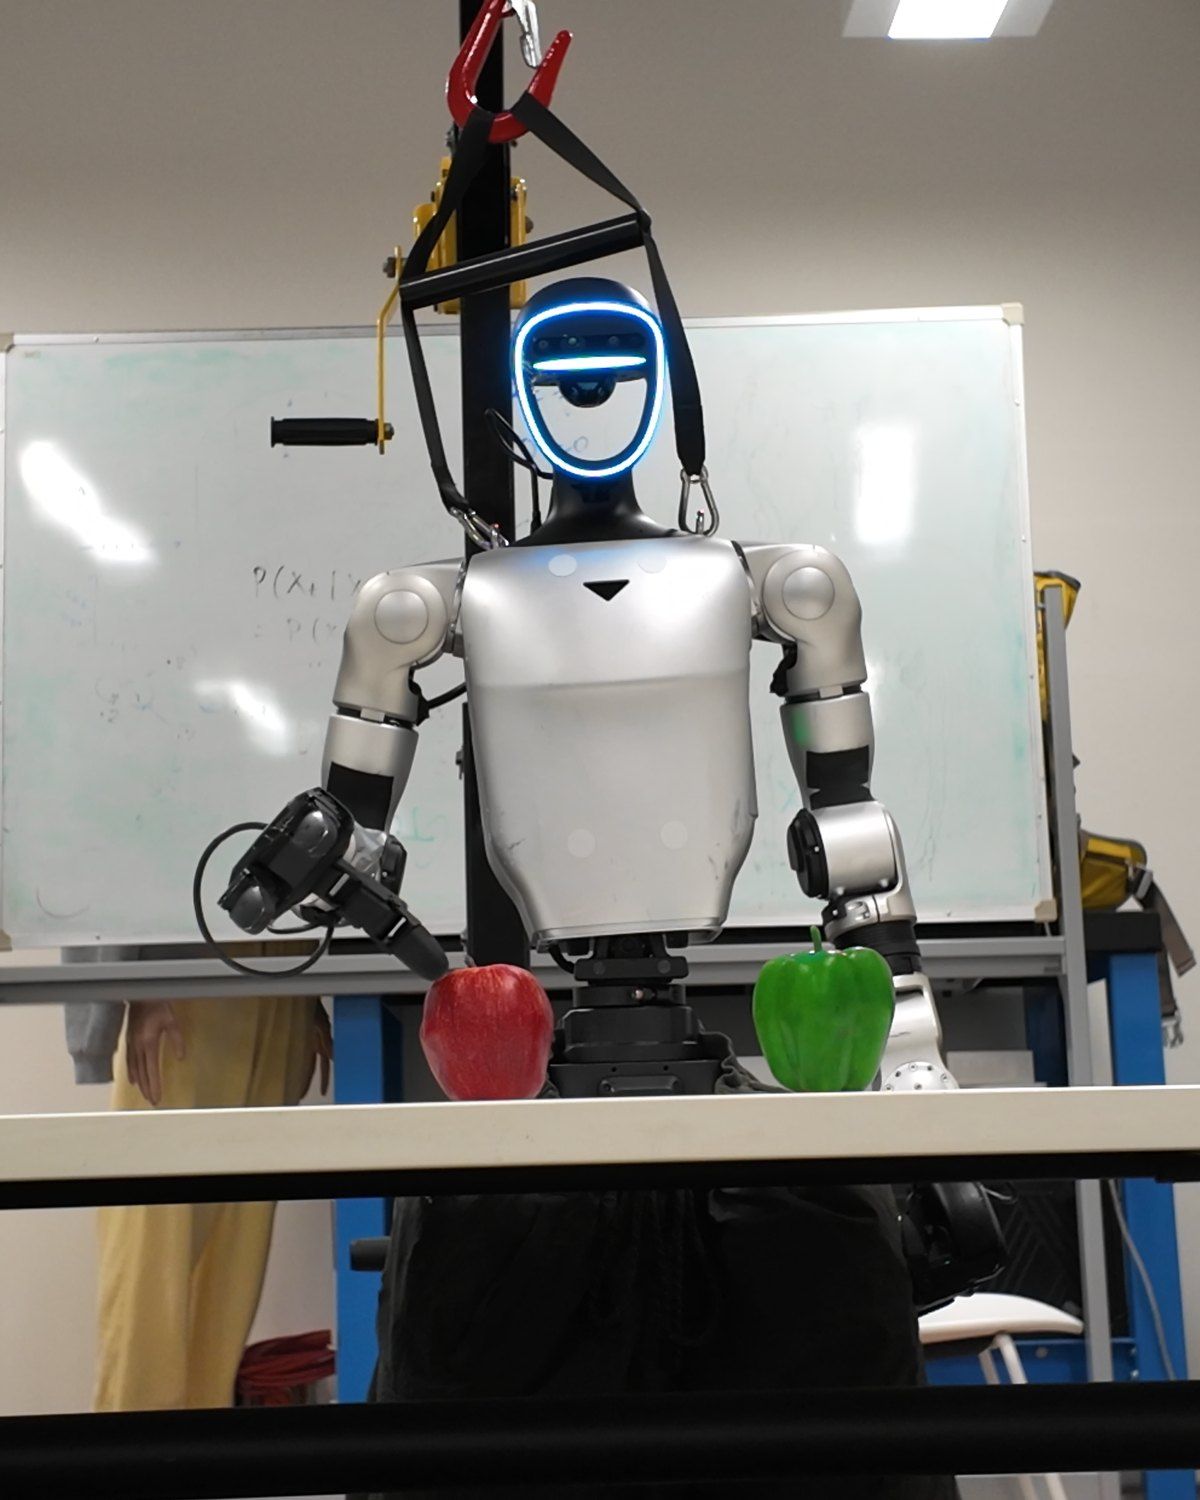
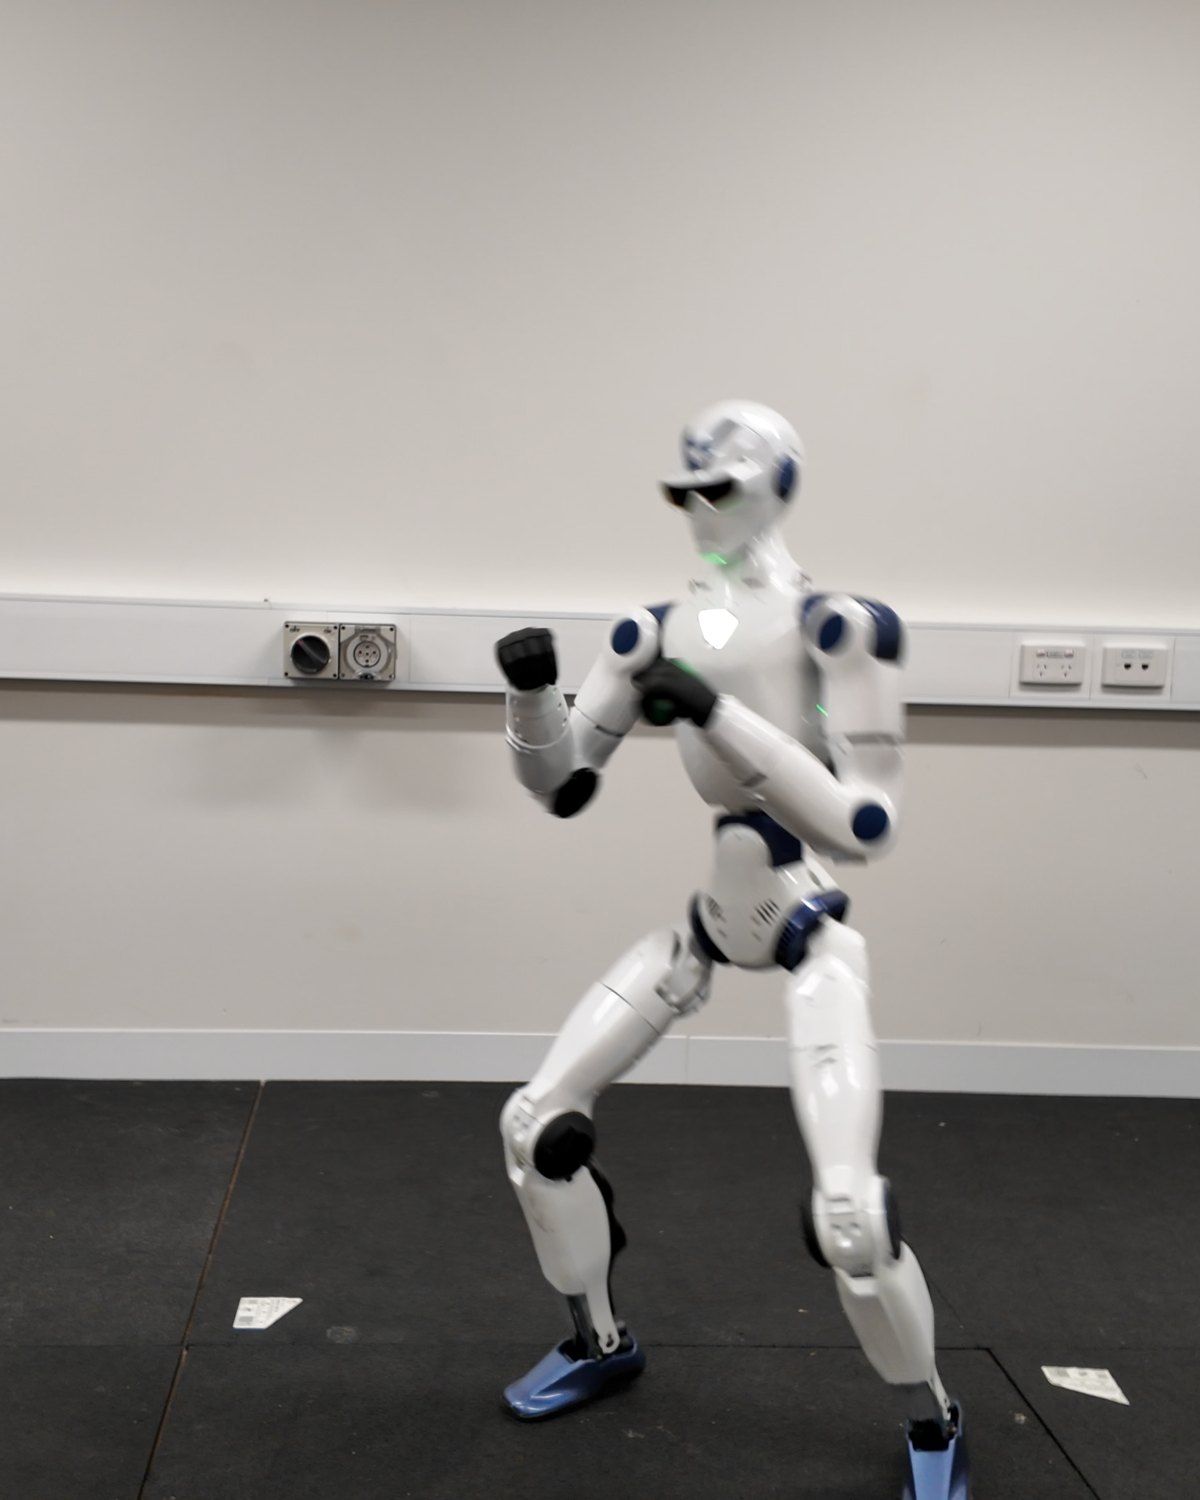
We study how network-side models and on-robot intelligence can coordinate sensing, planning and execution across multiple robots, while accounting for communication and computation constraints.
Project investigator: Haonan Zhou